Give a robot
a job.
Describe the task, the environment and the limits.
Download a starting brief for the conversation.
A place to beginInteractive 3D / The wrist interface
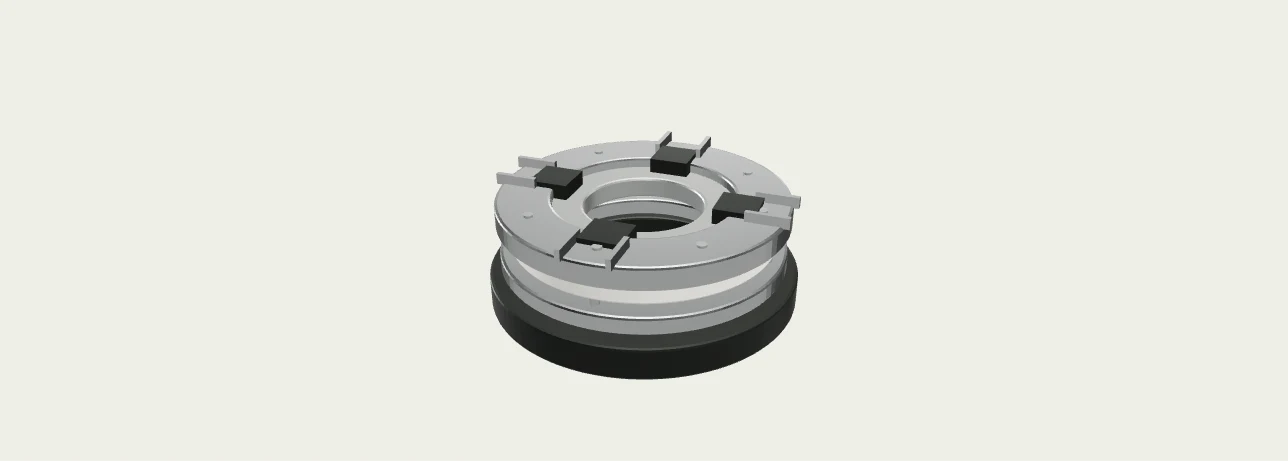
The wrist interface · Three-dimensional study
Define the connection.
A common interface is where a reusable hand meets a new machine. Mechanical retention, power and sensing all need explicit requirements.
Conceptual interface only. Locking, load capacity, electrical protection and cleaning remain engineering requirements.
Inside The wrist interface
- Retention keys
- Four retracting keys sketch a proposed mechanical connection.
- Interface stack
- Separated plates expose the locating and load-transfer layers.
- Contact ring
- An inner contact arrangement reserves a distinct path for electrical connections.
Start with the
physical problem.
Your answers stay in this browser tab. Download them as a text file, then share them when you are ready.
Prefer a conversation?
Write to insilicoExplore the connections
Turn an idea into a testable brief.
A useful engineering conversation begins with the job and its limits.
Describe what the robot should accomplish and who it helps.
Explanatory diagram · Select a connection to inspect its role.