Works / The insilico armOne connected development programme
One arm. Every connection.
Start with the complete assembly. Follow it from the hand that meets the world to the clamp that supports it—and into the mechanisms, signals and sensing that must work together.
Hand → arm / Development studyInteractive 3D / Hand to arm
Hand to arm · Three-dimensional study
Touch / Reach / Connectioninsilico / hand to armDrag to orbit · Shift + drag to pan · + / − zoomPreparing the study
Camera controls
One connected assembly.
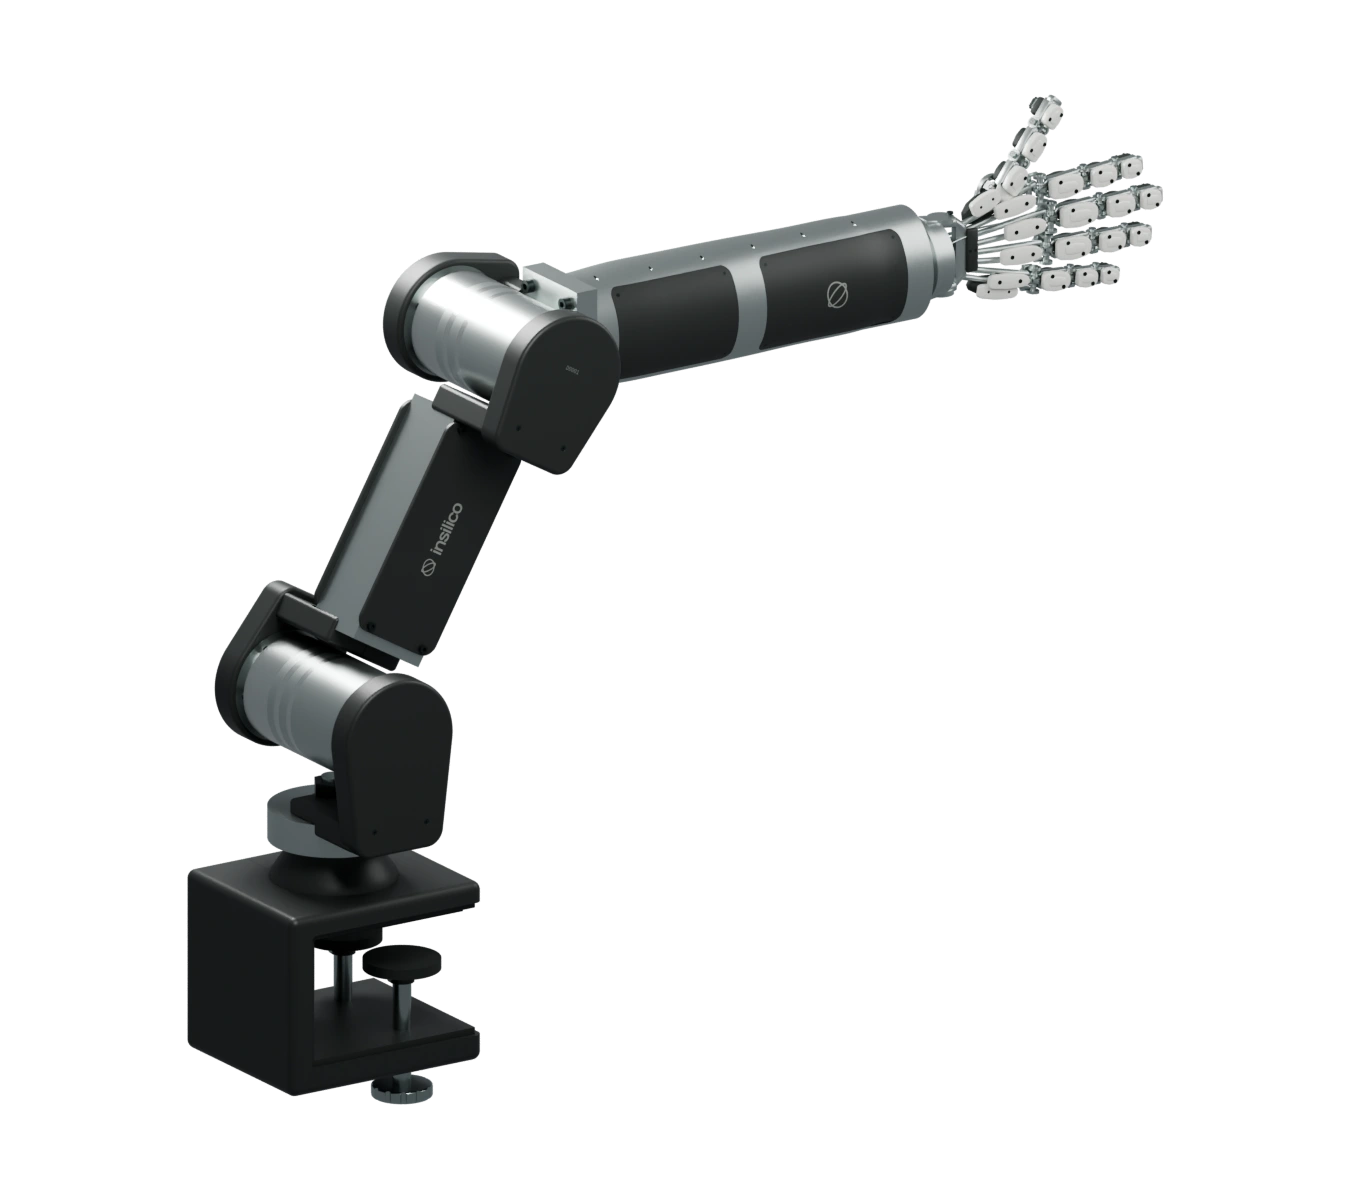
One continuous assembly, from fingertips to the table. Explore the complete arm, then separate its parts to inspect the construction.
Development study. Motion illustrates joint geometry; working tendon control and physical validation remain unfinished. Exploded view omits the two modeled wrist tendon strands; rigid guides and the passive electrical harness remain visible. Reassemble to inspect the actual modeled routes.
Inside Hand to arm +
Original hand
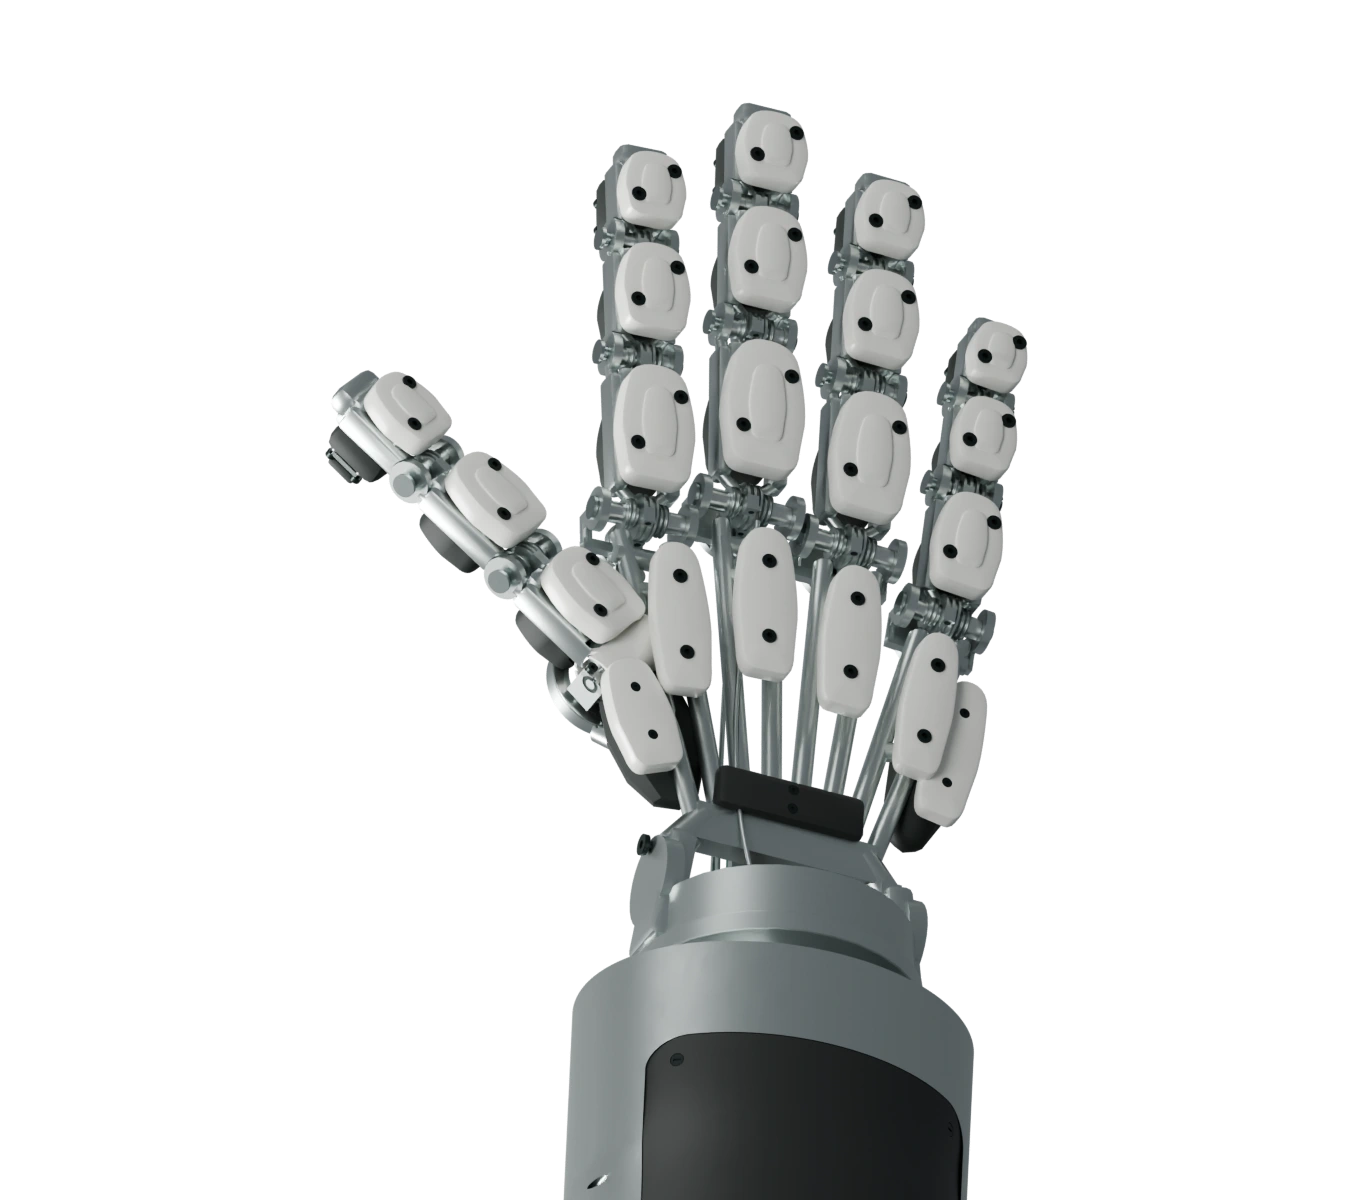
The anatomy-inspired hand preserves its articulated fingers, opposing thumb and layered contact surfaces. Three fingertips illustrate bounded joint motion. The middle finger stays still while its new tendon path is studied.
Wrist connection
A retained flange joins the hand and forearm. The selected fixed-wrist pose still has gaps at two middle-finger tendon terminals. All forty-two end-to-end routes, retention and moving-joint compensation remain unverified.
Forearm
The enclosure surrounds twenty-one custom finger-drive cartridges. Complete tendon routing and working finger control remain unfinished.
Elbow and shoulder
Custom planetary transmissions sit inside the arm joints. Motor and gearbox layouts are development geometry, not a demonstrated powered robot.
Desk clamp
The sculpted enclosure surrounds the retained clamp mechanism. The jaws and adjustment handles remain accessible.
Service access
Exploded inspection separates rigid parts and fasteners. The two modeled wrist tendon strands are omitted because their saved shapes do not follow separated parts. Rigid guides and the intact passive electrical harness remain visible; some guide ends are intentionally unconnected. Reassemble to inspect the actual modeled routes. These offsets are not an assembly procedure.
The complete arm
A place to begin. A system to build on.
A hand needs reach, support and a way to return information. The arm brings those requirements into one development platform, anchored to a suitable surface while we study the harder problem of useful manipulation.
Its two connected sections have different roles. The upper arm positions and supports. The forearm carries the finger drives close to the hand. Between them, the elbow turns reach into a useful workspace.
Four articulated fingers and an opposing thumb create the starting point for varied grasps. Replaceable contact surfaces make touch, wear and service part of the same design.
Inside the study +
The hand keeps its original proportions and mechanical appearance. Tendons are intended to transmit forces from the forearm; complete routing, useful thumb clearance and loaded grasping remain under development.
Structure, force and information cross the wrist by different paths. The flange carries loads. Tendons move the fingers. Insulated conductors carry power and sensor data.
Inside the study +
The current wrist is fixed. The selected pose leaves gaps at both middle-finger tendon terminals; all forty-two end-to-end routes remain unverified. Four modeled functional conductors—protected palm supply, ground, CAN high and CAN low—join passive boards, with a separate shield drain. Active boards and moving-wrist compensation are unfinished.
Forearm / Custom actuation
Keep the power close. Keep the hand light.
Twenty-one custom finger-drive cartridges sit behind the hand. A compact enclosure and removable panels give the lower arm a continuous form while keeping its mechanisms accessible.
Inside the study +
Motor, transmission, tendon take-up and sensing must fit together inside that envelope. The current drive geometry does not yet satisfy the one-second loaded grasp and sustained-use target. Complete 42-strand routing and common-length compensation remain open.
Complete assembly / The same source as the interactive study
Elbow / Reach
Move the hand through space.
The elbow changes the reach of the arm while the hand concentrates on contact. Rounded joint covers continue the form of the upper and lower arm around the transmission.
Inside the study +
Custom planetary transmission geometry sits inside the elbow and shoulder. The interactive reach study shows prescribed motion and source gear ratios; strength, braking, cable flex and protected powered operation remain unqualified.
Upper arm / Structure
Carry the load. Protect the connection.
The upper arm joins shoulder and elbow. Its structure must carry the hand’s loads while leaving a protected route for power, control and feedback.
Inside the study +
A hollow passage is only space for a connection. The final harness still requires retained connectors, strain relief, service loops and motion clearance through both joints. The structural load case must include the selected drives and the object in the hand.
Clamp / Foundation
A body that begins at a surface.
An accessible clamp anchors the arm to a suitable edge. Its sculpted housing, adjustment grips and centered support make the base part of the assembly’s design.
Inside the study +
The current geometry considers a nominal 20–50 mm surface edge. Capacity depends on the material, edge condition, contact pads and arm posture. Surface compatibility, clamp force and loaded stability need physical verification.
Sensing & control
A connected body must know its state.
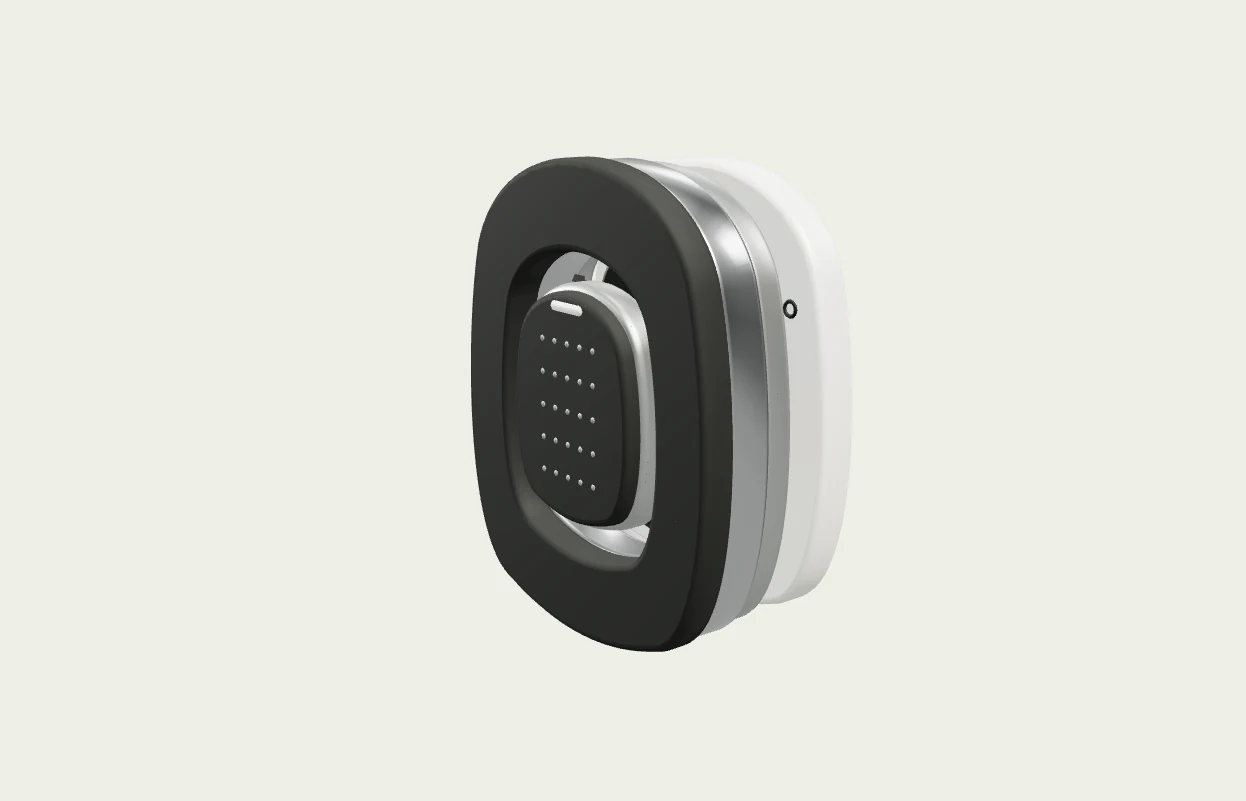
Contact-cartridge concept / Not an installed hand sensorSensing / Touch & vision
See the approach. Feel the contact.
Vision provides context before a grasp. Touch and joint feedback describe what happens once the hand meets an object. Both must be synchronized with the arm’s movement.
The camera architecture uses a rigid forearm mount that moves with the arm. Optical calibration, motion blur and the physical sensor installation remain development work.
Intended architecture / Installation in development
Electronics / The return path
Make the connection explicit.
Commands travel toward the hand. Position, contact and fault information travel back. The system needs both an electrical network and mechanical force transmission to become a working arm.
The current sensor wiring contract defines 123 functional segments: four modeled at the wrist and 119 still unrouted. Motor power stages, complete drive feedback, firmware and the rest of the arm harness remain unfinished. This is not the total robot wire count.
The target is manipulation of objects up to 1 kg, about one second per grasp and sustained use. CAD, circuit checks and offline control tests help us develop that system. They do not yet demonstrate a buildable or powered arm.