Does the probe disturb the hold?
Measure how the imposed motion reaches the object and the load-bearing frame. Mechanical crosstalk could overwhelm the signal we want.
Our initial mission is to build toward a humanoid inspired by human biology. We start with the hand: its form, its movement, and the extraordinary relationship between action and touch.
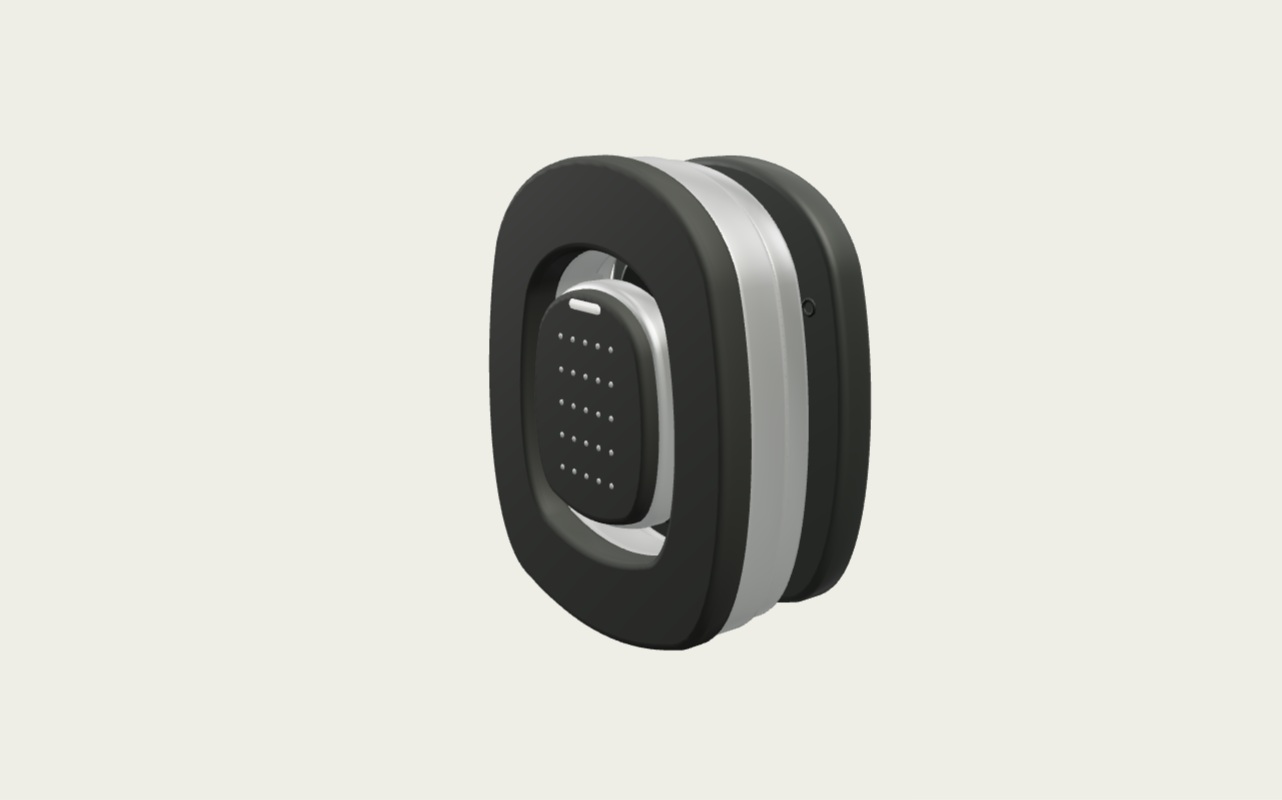
The investigating fingertip · Three-dimensional study
The outer pad sketches a load-bearing contact perimeter. A separate inner island carries the sensing surface. The intended separation is a hypothesis, not a demonstrated force isolation.
Speculative geometry study, magnified for inspection. Displacement is illustrative. No measured sensing resolution, gripping capability or food-contact qualification.
A kitchen refuses to be a fixed jig. Ingredients differ, surfaces get wet, tools change and a successful grasp can still bruise what it holds.
Culinary dexterity is one demanding test of the larger ambition. The precision associated with Michelin-level cooking remains a goal, not a capability we have demonstrated.
We are developing the custom actuation, touch and engineering tools behind a reusable hand architecture. The hand and wrist must connect to a future arm through explicit mechanical, electrical and control interfaces. The same architecture should support other robotics projects.
The cartridge asks whether a small sensing island can move without disturbing the main grasp. The outer pad and inner island still share a body, a cover and an object. Their forces will not simply disappear at a seam.
Measure how the imposed motion reaches the object and the load-bearing frame. Mechanical crosstalk could overwhelm the signal we want.
A replaceable skin needs sealing, cleanability and predictable friction. Heat, moisture, oils and repeated cleaning belong in the design from the start.
insilico connects mechanism development with a local engineering engine. Geometry, scoped calculations and independent review stay attached to the same revision.
This site presents the hand’s design, its component studies and the research questions behind them. A complete culinary hand, validated tactile sensing and measured kitchen performance remain future work.
Start a conversationThe hand joins our research in mechanics, sensing and physical intelligence.
A fingertip meets surfaces that vary in friction, shape and compliance.
Explanatory diagram · Select a connection to inspect its role.